3-DOF $30 Prototyping Robotic Arm
Motivation
A newly acquired 3D printer, a fresh ATmega2560, and an interest in robotics. As my Spring 2026 semester began, I aimed to use my limited free time in between classes, lab reports, and research to utilize these three things in one cohesive project.
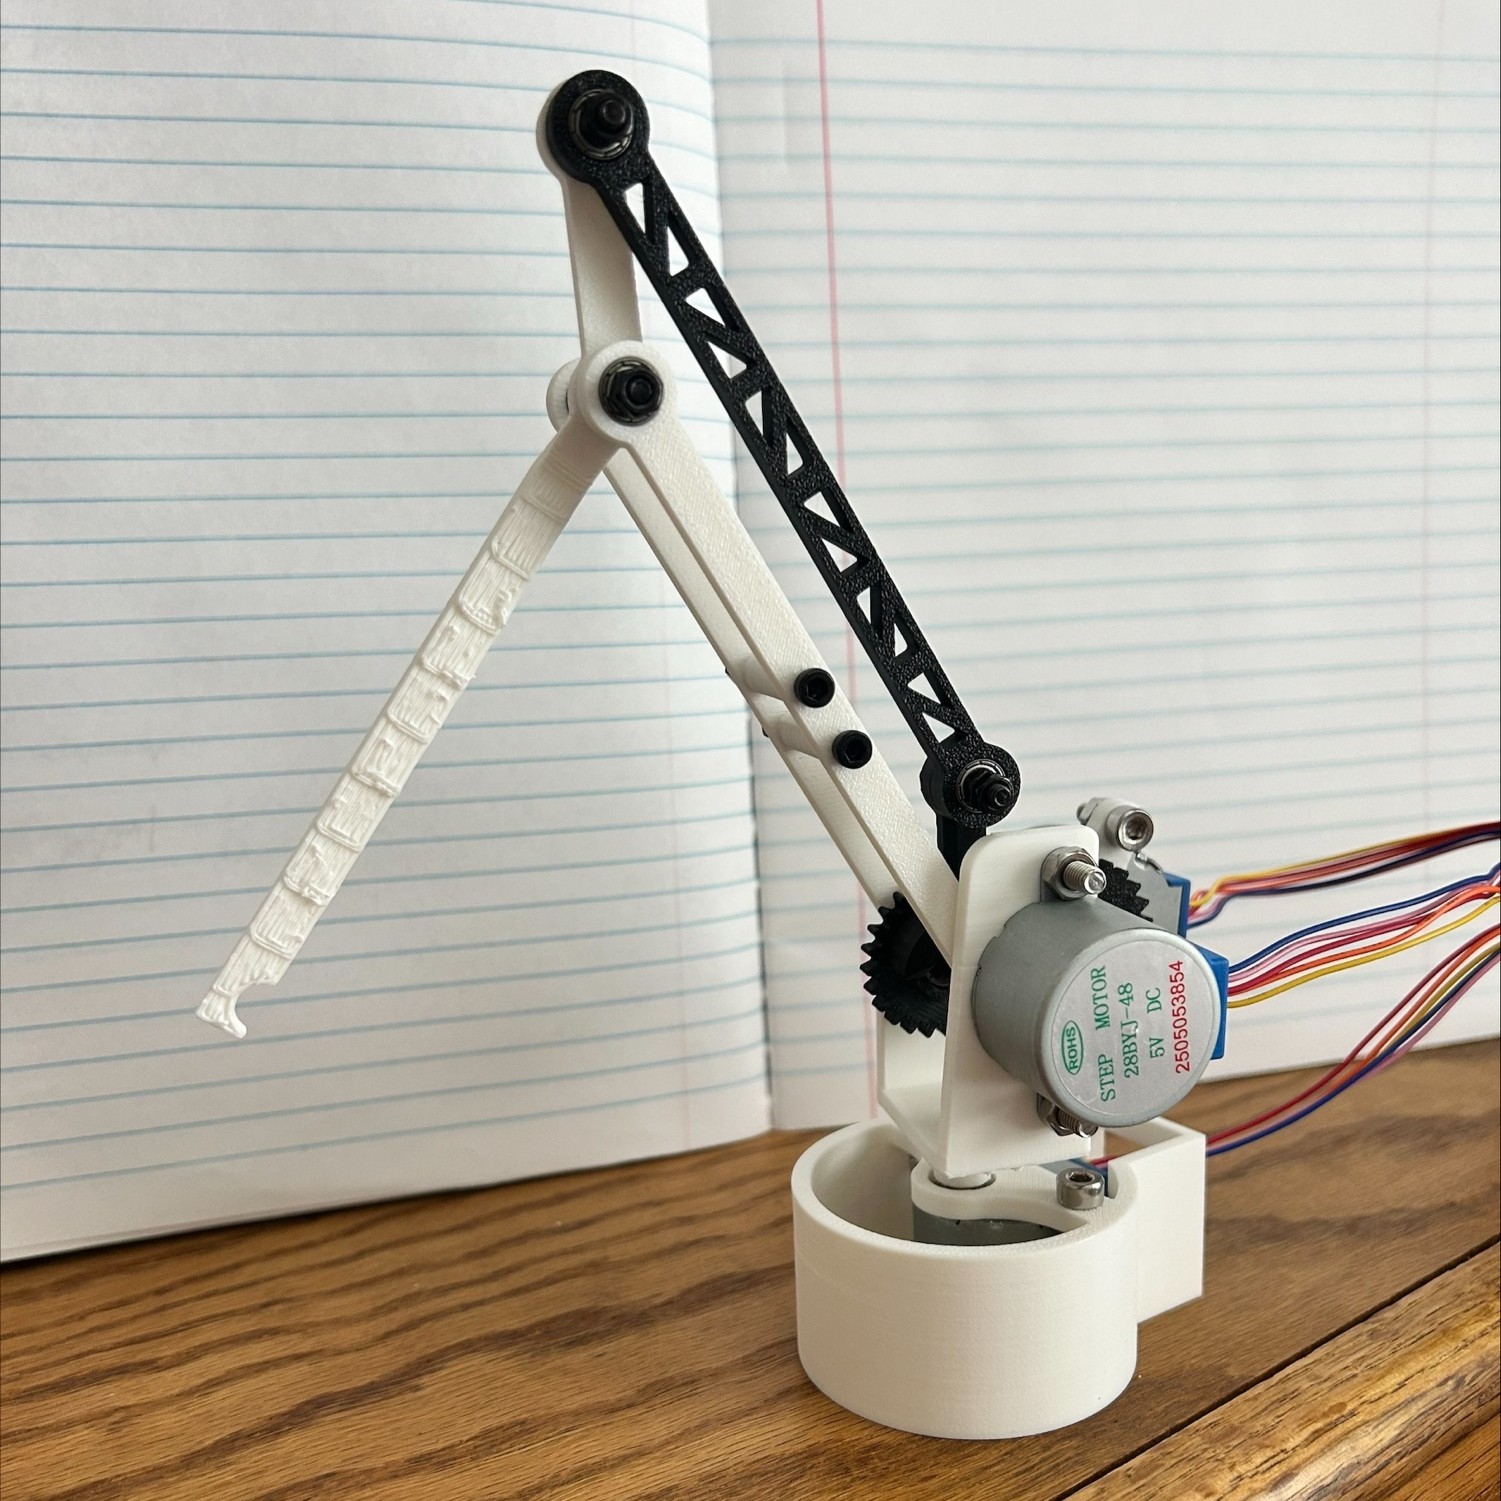
With this project, I created a simple yet intentional 3 DOF robotic arm that cost less than $30 to reproduce using Fusion360 for 3D modeling, unipolar stepper motors for movement, and an Arduino MEGA for controls.
I found this to be an amazing project to get familiar with the entirety of the design process. From modeling a hole with a +0.2mm tolerance to fit a bearing and designing the four-bar linkage to not collide with the frame to making sure I supply the motor driver with correct signals, I gained a great deal of experience with all aspects of this system.
Bill of Materials
| Item | Quantity | Cost | Notes |
|---|---|---|---|
| 28BYJ-48 Motor | 3 | $7.99 | Amazon Link |
| ULN2003 Driver | 3 | $0.00 | Included w/ motors |
| 608ZZ Bearing | . | . | . |
| M3 Screws & Nuts | . | . | . |
| . | Total: | . |